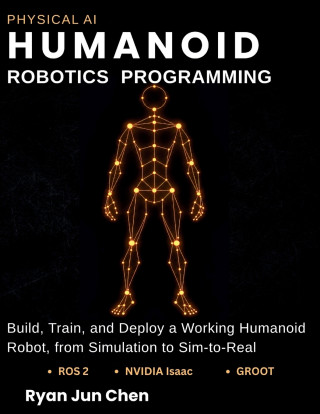
Kód: 54032244
HUMANOID ROBOTICS PROGRAMMING
Autor Ryan Jun Chen
You don't need a $50,000 robot to become a humanoid robotics engineer. You just need the right project.Every "AI robotics" resource right now is either a 20-minute YouTube demo that skips the hard parts, a $2,000 corporate bootcam ... celý popis


- Jazyk:
 Angličtina
- Väzba: Brožovaná
- Počet strán: 266
Nakladateľ: Independently published, 2026
- Viac informácií o knihe

28.33 €
Bežne: 30.45 €
Ušetríte 2.12 €

Skladom u dodávateľa
Odosielame za 10 - 16 dní
Mohlo by sa vám tiež páčiť
-
Threshing Day (Limited Deluxe Edition)
20.62 € -29 % -
Threshing Day (Wing and Claw Collection)
17.92 € -29 % -
Murdoku
14.91 € -21 % -
The Mirror of Infinite Endings
14.61 € -31 % -
The Art of Gravity Falls
36.54 € -25 % -
The Long-Lived King: An Original The Owl House Graphic Novel
16.21 € -30 % -
White Nights
4.50 € -14 % -
Berserk Deluxe Volume 1
38.95 € -27 % -
21 Days of Fear
16.61 € -27 % -
Court of Thorns and Roses 6
15.61 € -30 % -
Onyx Storm (Deluxe Limited Edition) (The Empyrean, 3)
24.22 € -26 % -
Lord of Mysteries, Vol. 4: The Faceless, Part I
16.91 € -15 % -
The Mirror of Infinite Endings
19.12 € -37 % -
Berserk Deluxe Volume 2
36.54 € -29 % -
Berserk Deluxe Volume 3
55.37 € -
Witch Hat Atelier: Grimoire Edition 1
35.14 € -29 % -
Fourth Wing
23.82 € -26 % -
Iron Flame
24.83 € -22 % -
Jojo's Bizarre Adventure: Part 7--Steel Ball Run, Vol. 9
19.12 € -22 % -
Protocols
14.31 € -29 % -
The Courage To Be Disliked
10.60 € -13 %
Darčekový poukaz: Radosť zaručená
- Darujte poukaz v ľubovoľnej hodnote, a my sa postaráme o zvyšok.
- Poukaz sa vzťahuje na všetky produkty v našej ponuke.
- Elektronický poukaz si vytlačíte z e-mailu a môžete ho ihneď darovať.
- Platnosť poukazu je 12 mesiacov od dátumu vystavenia.
Viac informácií o knihe HUMANOID ROBOTICS PROGRAMMING
Nákupom získate 69 bodov
 Anotácia knihy

You don't need a $50,000 robot to become a humanoid robotics engineer. You just need the right project.
Every "AI robotics" resource right now is either a 20-minute YouTube demo that skips the hard parts, a $2,000 corporate bootcamp, or a 600-page reference manual that never actually builds anything. You finish all three exactly where you started: able to talk about humanoid robots, unable to build one.
This book is different. It's one continuous project.
By the last page, you will have built, trained, and deployed a complete humanoid robot software stack, in the exact tools the industry actually uses (ROS 2, NVIDIA Isaac Sim, Isaac Lab, and NVIDIA's GR00T foundation model), culminating in one working capstone: a humanoid that's told to fetch a specific object, locates it, walks to it, grasps it, and confirms the task, entirely validated in simulation, with real deployment guidance if you have the hardware.
No prior robotics experience required. Just comfort with Python, a willingness to use a Linux terminal, and rusty linear algebra you're not afraid to dust off.
What You'll Build Inside:
- A physically accurate simulated humanoid, with real kinematics, dynamics, and sensors
- A bipedal locomotion policy trained from scratch with reinforcement learning
- A manipulation system fine-tuned from NVIDIA's GR00T foundation model on data you collect
- A full perception pipeline for object detection and grasp planning
- A safety-gated deployment pipeline built for real hardware, not just a demo
- One integrated capstone system, plus the exact portfolio and interview prep to turn it into a job offer
Humanoid robots are moving from research labs into Amazon warehouses, BMW factories, and Tesla production lines, and the engineers who understand this stack are being hired faster than they're being trained. This book teaches the current 2026 stack (ROS 2's latest distribution, Isaac Sim, GR00T), not a five-year-old tutorial pretending nothing's changed. Every chapter ships complete, runnable code, not fragments, plus a 30-error troubleshooting appendix built from the actual mistakes engineers hit in this exact pipeline.
You do not need to own a physical robot. Every core skill is fully exercised in simulation, the same professional workflow every real robotics team uses before touching hardware.
Whether you're a software engineer pivoting into robotics, a robotics engineer catching up on the foundation-model era, a student who wants a portfolio project that actually proves something, or simply someone who's watched the humanoid robotics demos and wants to understand what's really behind them, this book gets you there. Not with theory. With a working robot.
Stop reading about the humanoid robotics revolution. Start building it.
Scroll up and buy now!!
Parametre knihy
28.33 €
- Celý názov: HUMANOID ROBOTICS PROGRAMMING
- Podnázov: A Physical AI Project to Build, Train, and Deploy a Working Humanoid Robot with ROS 2, NVIDIA Isaac & GR00T, from Simulation to Sim-to-Real
- Autor: Ryan Jun Chen
- Jazyk: Angličtina
- Väzba: Brožovaná
- Počet strán: 266
- EAN: 9798177431802
- ID: 54032244
- Nakladateľ: Independently published
- Hmotnosť: 625 g
- Rozmery: 280 × 216 × 14 mm
- Dátum vydania: 27. September 2026
Osobný odber Bratislava a 13458 dalších
Copyright ©2008-26 najlacnejsie-knihy.sk Všetky práva vyhradenéSúkromieCookies

 25 miliónov titulov
 Vrátenie do mesiaca
 02/210 210 99 (8-15.30h)
